
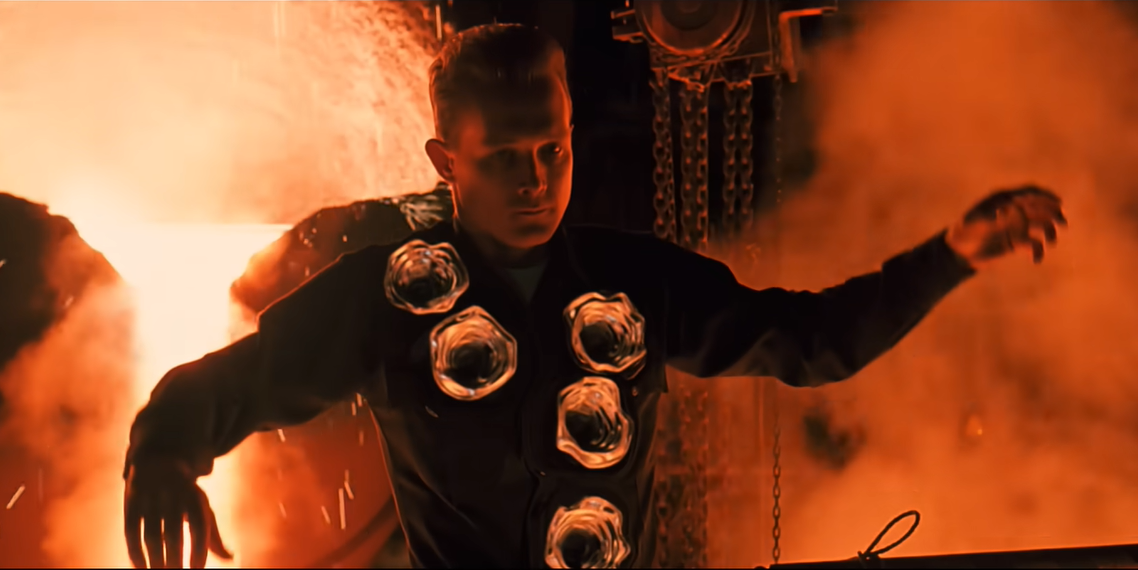
When James Cameron introduced the T-1000 in Terminator 2: Judgment Day back in 1991, the idea of a “mimetic polyalloy” didn’t land like a normal sci-fi invention. It landed like a rumor that shouldn’t be true. A robot made of liquid metal that could pour itself through bars, harden into blades, copy human faces, and still think clearly while doing all of it. No visible machinery. No joints. No weak spot.
It might be the ultimate upgrade a robot could achieve in physical form, at least if we set aside cosmic, universe-level powers like Marvel’s Infinity Ultron. Even without that scale of fantasy, the T-1000 represents something extreme, a machine that escapes fixed anatomy altogether.
Now, science fiction has a habit of introducing ideas that seem impossible at first, only for reality to circle back years later and borrow parts of them. Take smartphones, for example—the devices you might be reading this on today. Their concept was popularized by Star Trek. Similarly, The Jetsons gave us an early vision of the smartwatch.
That history, combined with today’s rapid developments in robotics, makes it reasonable to ask: Is the T-1000 pure fantasy, or could a liquid-metal robot like the Terminator exist in real life?
Also Read: Kawasaki’s Robot Horse CORLEO Is Turning Sci-Fi Into Reality
To answer that, it helps to look under the hood—or rather, beneath the liquid surface. The T-1000 isn’t just a stunt machine; it’s a collection of abilities that make it terrifyingly versatile. Looking at it in action, we can group these abilities into four broad categories: shapeshifting and regeneration, distributed intelligence, mimicry and sampling, and function without fixed anatomy.
Breaking the T-1000 down this way separates the spectacle from the science—and lets us ask how much of it could one day step off the screen and become reality.
The Shapeshifting Ability
Moving into the first pillar of the T-1000’s anatomy, we have to confront the most jarring visual from the film: a solid machine that simply decides to stop being solid. In classical engineering, metals are defined by their rigidity. If you want to change the shape of steel or aluminum, you need an industrial furnace and thousands of degrees of heat to first change its state. Yet, the T-1000 achieves this state transition at room temperature, flowing through a security gate as a liquid and stepping out the other side as a solid, polished officer.
The films explain this ability through the idea of a “mimetic polyalloy,” a fictional liquid metal that makes up the T-1000’s body. In the real world, robotics has usually worked in two separate modes. You either have hard robots built from rigid parts like gears and motors, or soft robots made from flexible materials such as silicone and rubber.
Researchers have tried combining these approaches, creating machines as impressive as the Octobot. But even that is still very far from a Terminator. These systems can bend and deform, but they cannot flow, harden, and reshape themselves the way the T-1000 does.
Still, if we look for the closest real-world hint of shapeshifting, there is something interesting. In a recent breakthrough, researchers in China created a new phase-shifting material called a “magnetoactive solid–liquid phase-transitional machine.” They embedded microscopic magnetic particles in gallium—a metal with a very low melting point of about 29.8 °C—to build a material that can respond to invisible commands. When exposed to an alternating magnetic field, these particles vibrate intensely, heating the metal from the inside and triggering a transition between solid and liquid.
Also Read: EngineAI T800: Humanoid Robot Performs Incredible Martial Arts Moves
In a demonstration video, the researchers showed a small, humanoid-shaped robot that could melt itself to “escape” a miniature prison cell. At the very least, this shows that we now have materials that can shift from solid to liquid without relying on an industrial furnace or extreme external heating.
But becoming liquid is only a small part of what the T-1000 does. We can’t forget the scenes where it takes shotgun blasts, is riddled with bullet holes, and then slowly regenerates itself back into a perfect humanoid form.
In the Chinese research, the robot was reshaped after escaping the cell by molding it back into its original form. That works for a demonstration, but true regeneration is a different problem. Cooling can turn liquid metal solid again, but forming a specific shape on demand would require precise control of the material at a microscopic level. In the Terminator’s fiction, that role is handled by a so-called molecular brain.
The “Molecular Brain” (Distributed Intelligence)
In the movie, the T-1000 lacks a traditional “kill shot” because it lacks a traditional center. There is no cockpit, no hard drive, and no motherboard tucked behind its silver ribs. Instead, Skynet’s assassin uses a “molecular brain“—a distributed intelligence network where every single particle of the liquid metal is a part of the computer. If you blow the machine’s head off, the puddle on the floor doesn’t just sit there; it thinks, it recalibrates, and it crawls back toward the main mass.
Within the film’s internal logic, the T-1000 is made of mimetic polyalloy, an artificial liquid metal composed of billions of microscopic units. The key idea is that this material is programmable matter. Each unit is pre-programmed and self-similar to others, functioning as an identical part of the whole. No single unit acts as the brain; instead, when these billions of particles assemble into the Terminator’s form, they behave like a hive mind—a collective intelligence in which awareness and control emerge from coordination rather than from a central processor.
At first, programmable matter may sound like pure science fiction. However, there is a real research field called claytronics that aims to explore this very idea. It isn’t imaginary or purely theoretical; active research and physical experiments already exist, attempting to turn programmable matter from a concept into a working technology.
Claytronics focuses on creating tiny programmable robots, known as catoms (short for claytronic atoms), that can physically connect with one another to form different shapes and objects. This technology aims to give physical form to digital information, allowing a virtual 3D object to exist in the real world.
You can think of it this way: in a computer simulation, millions of tiny particles can be arranged and rearranged to create different 3D shapes. Claytronics attempts to bring that same idea into reality by turning those particles into microscopic robots, capable of moving, connecting, and reorganizing themselves to form real three-dimensional objects.
While major institutions like Carnegie Mellon University and Intel are actively working on claytronics, the smallest catoms achieved so far are still 3.6 millimeters in size. Shrinking them further is extremely difficult, because each catom must contain processors, sensors, communication systems, and other complex systems, all packed into an incredibly small volume.
And even if researchers managed to build catoms not at the nanoscale but at the microscale, the result would still fall far short of a T-1000–like machine. Such a system would resemble Marvel’s Sandman because of the comparatively large particles and weak adhesion between them.
This may feel discouraging, but that isn’t the final verdict. As we’ll see later, how claytronics can contribute to the path toward a T-1000–like system when combined with other technologies.
Also Read: World’s Smallest Autonomous Robot That Can Sense, Think, and Act
Mimicry & Sampling (Haptic Scanning)
One of the T-1000’s most unsettling abilities is its ability to sample and mimic molecular structure. It doesn’t look at a person and copy them; it requires physical contact to reproduce their appearance. On the surface, this sounds like its most impressive trick. But this isn’t actually what makes the T-1000 so cool. Whether it wears the face of Robert Patrick or Lee Byung-hun doesn’t really matter. The real unease comes from its other abilities, like shapeshifting body and the ability to regenerate after damage.
However, if we were to include the copying feature in a real-world system, physical contact wouldn’t necessarily be required. Visual 3D scanning alone could capture an object’s external shape. This technology already exists today; modern devices can generate detailed 3D models simply by observing an object. Once a 3D model is generated, a programmable-matter system, such as one made of catoms, could then replicate that scanned shape.
Even then, perfect copying would remain out of reach or extremely difficult. The system might reproduce shape and color with impressive accuracy, but it would still fail to capture the subtle feel of a real human. From a distance, in a crowd, or under low light, it might pass as human. Up close, however, it would feel wrong, more like a polished metal statue than a living person. Although it might not feel exactly human, we want a killer machine, not a movie actor.
Function Without Anatomy and Sensors
Moving toward the most alien aspect of the T-1000, we find a machine that defies the most basic rule of biology: you need a skeleton to move. In every other humanoid robot we’ve built—from the industrial arms in car factories to the bipedal humanoids of Boston Dynamics—there are joints, servos, and rigid frames. But the T-1000 moves like a predatory shadow. It doesn’t walk so much as it “flows” forward, a masterclass in Locomotion Without Anatomy.
What we discussed earlier about programmable matter made of catoms reveals a key limitation for dynamic motion. Most proposed catom systems rely on electrostatic forces to move, attach, and rearrange themselves. These forces are precise but weak. As a result, performing fast, high-force, dynamic actions, such as punching or striking, would be extremely difficult. The motion would be slow, and under a strong impact, the structure would likely break apart into many pieces rather than behave as a single, solid body.
So how can a material move quickly and powerfully without breaking apart? Recent advances in soft robotics provide a clue.
Researchers are already working toward achieving soft fluidic actuation, where controlled fluid motion enables a robot to move. One of its key mechanisms is the Marangoni effect, which lets liquid metals move by manipulating surface tension. By applying a tiny electrical charge to a drop of liquid metal, surface tension can be altered on one side. This gradient causes the droplet to “push” forward, creating a form of propulsion that requires zero moving parts. Though these systems are still at an early stage, they already open the door to movement without anatomy.
Also Read: Humanoid Robot Kicks Its Trainer in the Groin
Another unsettling detail about the T-1000 is that it doesn’t have fixed sensors for vision and hearing. There are no “eyes” or “ears” in the usual sense. Instead, its entire body functions as a sensing surface, able to gather information from any point of contact.
Translating this idea to the real world is tricky. Liquid metals such as gallium can conduct sound waves efficiently, which suggests that sensing vibrations through a liquid body is possible. However, because the material is constantly flowing and reconfiguring, those sound waves would be continuously distorted. That motion would scramble the original signal, making clean sound perception far more difficult than it appears in the films.
Extending this idea to vision introduces an even harder problem. Full-body image sensing would require vast numbers of tiny image sensors distributed throughout the material, each capturing only a small fragment of the scene. Those fragments would then need to be coordinated and mathematically stitched together to produce a coherent visual understanding of the surroundings.
While sub-millimeter image sensors already exist and can likely be made even smaller, the real bottleneck isn’t sensor size, but integration. Combining millions of local image streams into a single, real-time visual model while the body itself is constantly moving and deforming would be computationally overwhelming. Vision, in this case, becomes less about seeing and more about synchronizing chaos.
Final Synthesis
If we step back and combine the pieces discussed so far, a surprisingly coherent picture begins to emerge. Not the exact way T-1000 is made, but perhaps the most realistic path toward something functionally similar.
First, we already have experimental materials capable of solid–liquid phase transitions without conventional heating. Magnetoactive phase-transitional machines show that liquid metals can be switched between solid and fluid states using magnetic fields alone. This solves one of the biggest cinematic leaps in Terminator 2: changing phase without an external furnace.
Second, researchers have demonstrated electrically and magnetically driven liquid-metal motion, where droplets move, split, merge, and reconfigure by manipulating surface tension and internal forces. More intriguingly, some studies have shown that shape changes in liquid metal can be used to represent logic states, suggesting a primitive form of computation embedded directly in the material itself. In other words, shape, phase, and signal can already be linked.
Third, while claytronics is far from complete, catoms are a credible candidate for functional microscopic units. Even if they never reach true nanoscale, microscale catoms could still contain processors, sensors, and communication systems. On their own, they are too large and weakly bonded to behave like the T-1000. But they don’t necessarily need to form the body directly.
A more plausible architecture is hybrid. Instead of rigidly connecting to one another, catoms could be embedded within or dispersed throughout a phase-changing liquid-metal matrix. Inside this material, they would not act as mechanical building blocks, but as control nodes. Each catom could generate and respond to magnetic and electric signals, allowing it to coordinate with its neighbors and control the phase and movement of the liquid metal of its surroundings from within.
Also Read: AgiBot Q1: The Humanoid Robot That Can Easily Fit in Your Backpack
In this framework, the movement of our real-life T-1000 becomes conceptually feasible. Rapid solid–liquid transitions on the order of milliseconds have already been demonstrated, although integrating such mechanisms into a catoms will be a major challenge. If achieved, this could allow localized parts of the body to stiffen or soften almost instantly. Combined with internal magnetic and electric actuation, this would enable flowing motion punctuated by transient rigidity, supporting dynamic movement rather than slow, purely deformative behavior.
Sensing could also be distributed. Image sensors embedded in catoms could contribute fragments of visual data, while temporary local solidification of a body part could reduce acoustic distortion for sound sensing. Perception would no longer come from discrete “eyes” or “ears,” but from statistical integration across the body.
In this model, the robot’s brain emerges not from the liquid metal itself, but from the coordinated interaction of millions of catoms. These catoms provide sensing, computation, and control. The liquid metal supplies mass, continuity, self-healing, and force transmission, functioning as both the body and the motherboard for the distributed catoms, which are not in direct physical contact with one another.
Put together, this system may not be a perfect imitation of the cinematic T-1000, but it would capture something more important: a robot without a fixed anatomy, whose intelligence, perception, structure, and motion all emerge from coordinated matter rather than rigid design.
At this stage, it may feel as though a real-world analogue of the T-1000 has been conceptually assembled. However, several fundamental obstacles remain between theoretical plausibility and physical realization. The most immediate is energy: sustaining continuous phase transitions, electromagnetic actuation, distributed sensing, and computation across the entire body would require an enormous and tightly managed power budget, along with effective heat dissipation.
Also Read: Michigan Tech Students Build Robot in 72-Hour Challenge
Equally challenging is coordination and maturity. This system depends on millions of microcomputers operating inside a noisy, conductive environment, where electromagnetic interference, latency, and signal collision could easily disrupt collective behavior. Orchestrating such a system would demand software of unprecedented complexity, capable of maintaining coherent global control while each unit performs local tasks.
Compounding this, many of the core technologies involved—micro-scale catoms, rapid reversible phase-transition materials, and liquid-metal computation—remain in early experimental stages, leaving open the question of whether they can scale reliably or efficiently enough to support such a system.
So, is the Terminator’s T-1000 liquid metal robot scientifically possible? The answer is likely yes—but would not be built in the exact way shown in the movie, and only if the supporting technologies advance far enough.